More capabilities.
Fewer barriers.
High-performance robotics, engineered to be reliable, accessible, and scalable.
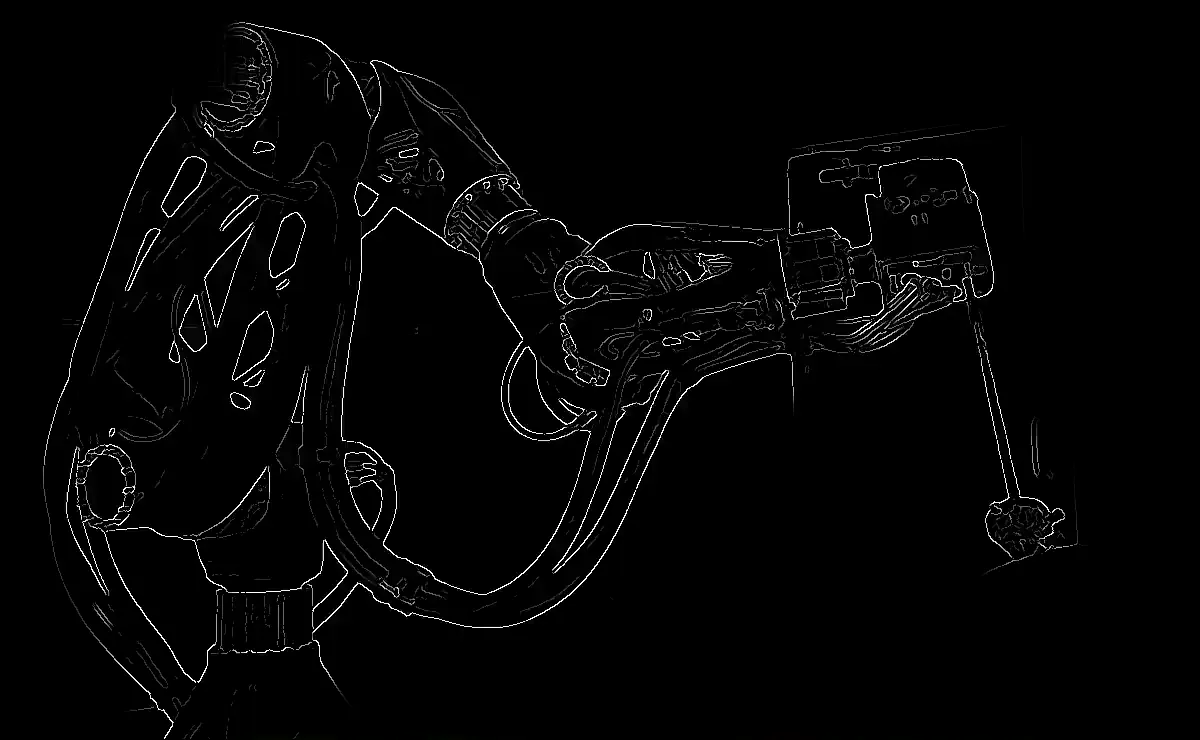
Traced from footage of the Robotic Surgical Trainer. Select a joint.
This is the real machine.Robotic Surgical Trainer, under teleoperation. The same frame as the drawing.
Product 01 Surgical Simulator
Real input.
Simulated surgery.
- 01 Bottom left: Real input. Haptic feedback.
- 02 Left: A simulated robot in a virtual operating room.
- 03 Right: Dynamic tissue deformation under instrument interaction.
A simulation environment with a glasses-free 3D console for the surgeon and a real input device with haptic feedback. Trainees practise robotic surgical tasks on simulated anatomy, with no physical robot required.
The Surgical SimulatorProduct 02 Robotic Surgical Trainer
Train on a robot.
Not on a simulator.
A physical robotic arm, operated through teleoperation, handling real instruments on a real training task. Hands-on robotic surgical skills training, on the machine itself.
The Surgical TrainerYour hand moves. The robot follows.
Three views from a single recording of the Robotic Surgical Trainer. They run on the same clock, so what the hand does on the left is what the instrument does on the right.
- 01
Hand on the controller
The operator guides a hand controller at a desk.
- 02
Robot moves the instrument
The arm carries a real instrument through a real port.
- 03
What the camera sees
The task, viewed through the endoscope.
Robotics,
built for problems
that matter.
Product 03 Robotic Endoscope Holder
Effortless hand guidance.
Precise positioning.
On the hardware The endoscope is mounted on the robotic arm. The user steers the scope effortlessly, simply by guiding the arm by hand.
Try it Guide the scope yourself
The holder carries the endoscope on a robotic arm. Guide it by hand (drag the scope) and the robot keeps it pivoting about the port: a remote centre of motion.
- 01
Position
The arm brings the scope to the port.
- 02
Orient
The scope pivots about the port to aim the view.
- 03
Maneuver
Guide it by hand; the constraint holds.
Product 04 Intelligent Vision Engine
See.
Measure.
Guide.
An intelligent vision engine for surgical robotics. AI-powered, low-latency perception that transforms 3D laparoscopic imagery into spatial understanding for robotic guidance, measurement, and interaction.
- 01
See
Stereo imagery from a clinical 3D laparoscope.
- 02
Measure
Turned into spatial information, with low latency.
- 03
Guide
Delivered to the surgeon's display.
Our partners.
AGIHF
IIT Guwahati
ROBOSS
Our first frontier:
medical robotics.
The journey
goes beyond.
Building on our expertise in medical robotics, we are extending our robotics capabilities to new verticals.
Vertical 01 Medical robotics
Vertical 02 Coming soon: Industrial robotics
Vertical 03 Coming soon: Space robotics
Vertical 04 Coming soon: Defense robotics
Deep-tech robotics.
Engineering-led.
Indigenously built.
Valeri Robotics designs and builds advanced robotic systems in Assam, India.
Our journey begins with medical robotics, where precision, control, and reliability are non-negotiable. Our first systems span surgical simulation, robotic training, and robotic endoscopy, built around a common robotic arm platform.
We build for accessibility without compromising quality. Every system is engineered to deliver the performance and reliability expected of advanced robotics, while making that technology accessible to more applications.
Build the future
with us.
Hospitals, training centres, researchers and engineers: if you want to work with real robots, write to us.